

Opinion: Moravec’s paradox explains why physical AI needs a sense of touch
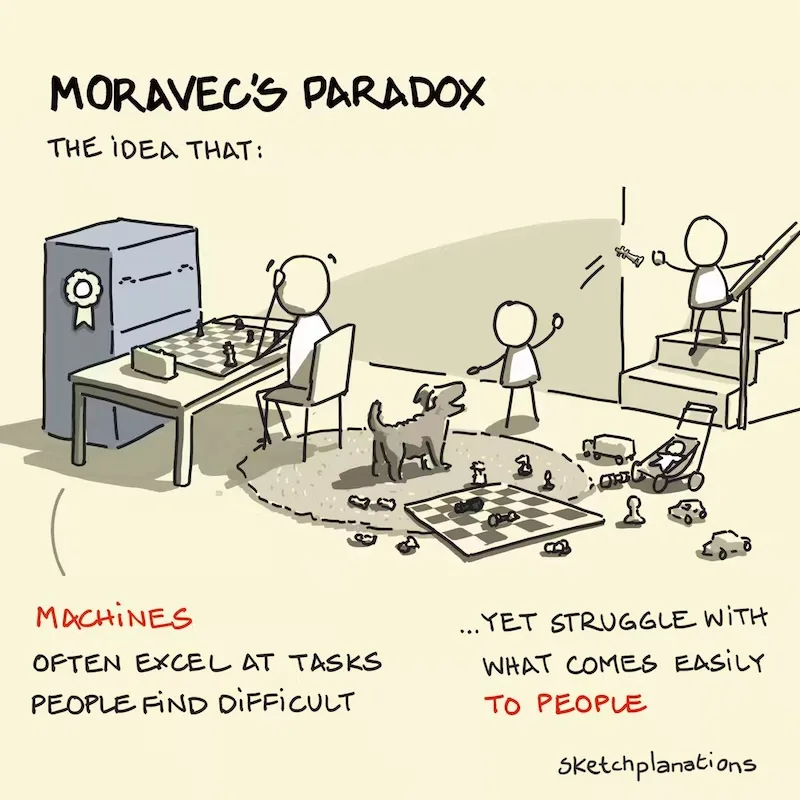
AI-generated summary Ron Zukerman of Vishay Precision Group reports that physical AI and robotics face challenges because physical movement cannot be solved by language models alone. The report notes that camera-based vision systems lose line of sight when a robotic gripper closes around an object, making force and torque sensing necessary.